Skip to content
View from a brownfield warehouse

Why the industry left the brownfield warehouse behind

A founder's perspective on the automation gap that still exists — and why Grab™ was built to fill it.

The warehouse automation gap nobody talks about

Walk through most large-scale distribution centres today and you will find impressive automation. Conveyor systems moving thousands of units per hour. Automated storage and retrieval systems stacking pallets with millimetre precision. Sophisticated warehouse management software orchestrating it all.

These systems are genuine achievements.
They solved a real problem, at scale, for the operations that could justify the investment.
people walking away in a warehouse
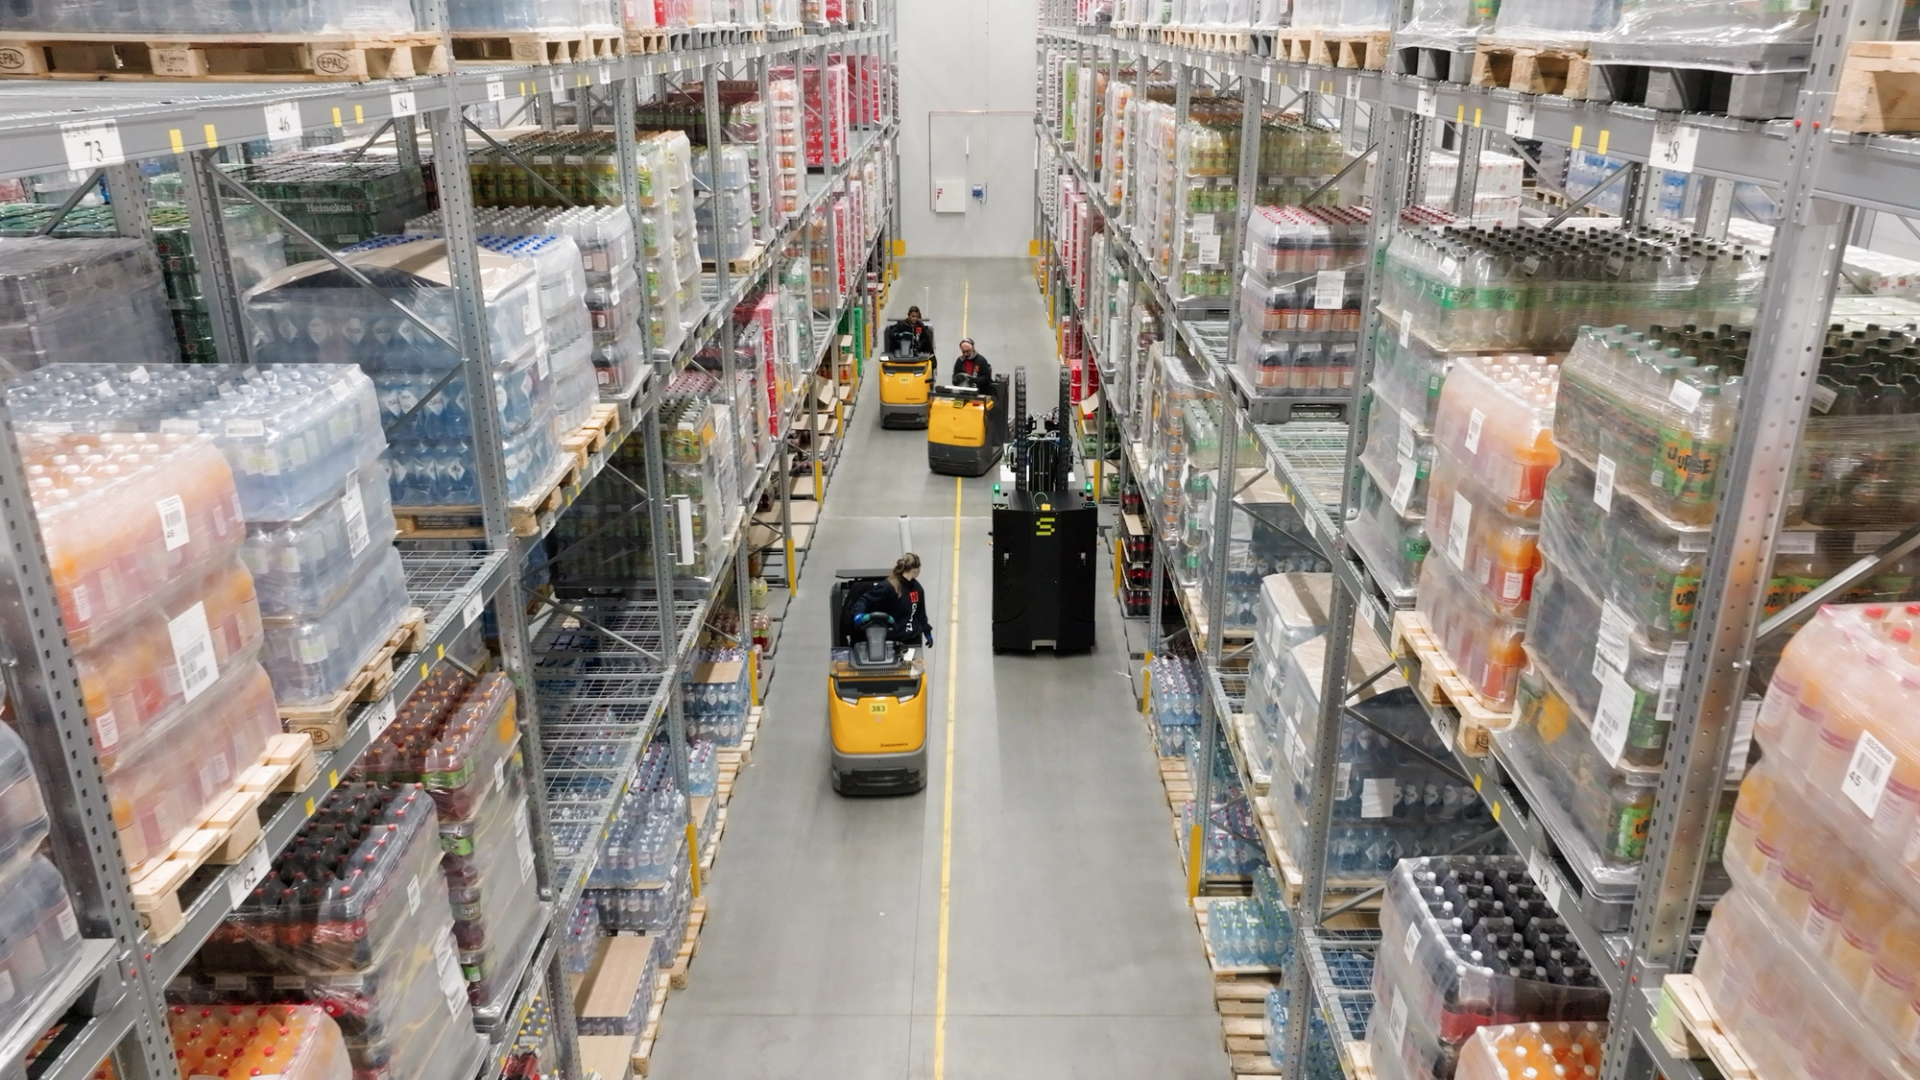
But visit a regional distribution centre.
An existing warehouse built years ago, running a mixed SKU range, with volumes that fluctuate by season — and you will find something different:
  • Dozens of people walking kilometres every shift
  • Lifting cases that can weigh anywhere from 1 to 30 kilograms
  • Picking orders by voice prompt or paper list.

Not because the operation is behind. Because for this type of warehouse, the automation industry never really built a solution that fit.

When a well-run warehouse hit its limits

Through the 2010s, the pressure was building across regional distribution in Northern Europe.

And then the ceiling arrived:

  • Wages rising structurally
  • Absenteeism a permanent drag on capacity planning
  • Recruitment for picking roles getting harder every year
  • The roles were physically demanding, repetitive, and increasingly difficult to fill at any sustainable wage

Solwr was founded by someone who ran one of those warehouses. A mid-sized regional grocery distribution centre in Norway, operating with lean principles, trained staff, and every efficiency improvement that process discipline could deliver.

The next step was automation. But the search for a solution revealed a gap in the market.

The missing solution for mid-market warehouses

Large-scale automation (AS/RS, full conveyor systems, goods-to-person based automated distribution centers and similar) was built for a different customer profile. Greenfield sites. Eight-figure capital budgets. Multi-year implementation timelines. Operations with the volume to justify a complete rebuild of their physical environment.

For a mid-sized brownfield warehouse with an existing layout, a realistic capital budget, and a labour problem that needed solving now — not in three years after a facility redesign — there was no solution.

The gap was not a failure of innovation by the large-scale providers. They built excellent systems for the customers they were designed to serve.

The gap was a market positioning question: nobody had built for the brownfield, mid-market, case-picking operation.
Quote Image
Torbjørn Krogen
CEO, Solwr Robotics

CeMAT 2014 confirmed the gap was real

In 2014, Solwr's founder Torbjørn Krogen travelled to CeMAT in Hanover, the then leading intralogistics trade fair, with a specific brief:
Find an AGV combined with a robotic manipulator capable of picking and stacking cases in an existing warehouse environment.
LogiMAT
The technology components existed separately:
  • AGVs had been in industrial use for decades.
  • Robotic arms were established in manufacturing.

The combination: a mobile robot that could travel to the goods and physically handle full cases, replacing person-to-goods picking with what's now best described as robots-to-goods, seemed like the obvious next step.
It didn't exist. Not for case picking, and not for a brownfield warehouse.
What the search confirmed was that the gap was real — and that the need was too widespread and too persistent to remain unaddressed.

Built in real warehouses, not in a laboratory

What followed was harder than anticipated.

Combining autonomous navigation with physical case handling in a real warehouse turned out to be a harder engineering problem than expected. Real warehouses bring:

  • Varying case weights
  • Mixed SKU dimensions
  • Imperfect racking
  • Uneven floor conditions

What made the difference was developing the mobile picking robot Grab alongside the market rather than in isolation.

Key customers and distribution partners provided access to real warehouse environments for continuous R&D, along with the kind of honest operational feedback no lab test can replicate.

That process took years. It was not a straight line. But it produced something that laboratory-first development rarely achieves: a robot that works in the conditions real warehouses actually operate under.
Quote Image
Torbjørn Krogen
CEO, Solwr Robotics

Technology for operations that can't start from scratch

12 years after Torbjørn walked the aisles of CeMAT looking for a robot that didn't exist, Grab is running in live operations across multiple sites.

These are no longer promises, they are measurable outcomes, verified in real brownfield warehouses:

  • Pick accuracy
  • Reduced physical load on the workforce
  • Operational continuity

The brownfield case-picking gap that defined the 2014 brief remains one of the most underserved segments in warehouse automation. The warehouses that keep food on shelves, supply the wholesale trade, and move the goods European households consume every week aren't edge cases. They're the majority of warehouses operating across Europe today.

FAQ

  • Brownfield means existing infrastructure — and is usually a building not originally designed for automation. That makes it harder to automate, since access is often limited, space is tight, and operations can't stop while you retrofit.

  • We built Grab primarily to shift warehouses away from traditional person-to-goods picking. It's a strong fit for grocery, where SKU variety is high, but it holds up well in other industries too.

  • Physical deployment takes about a week, if WMS integration is already in place.

Illustration of bulb
Ready to start automating your brownfield site?
We're happy to walk you through automation solutions for your specific environment.